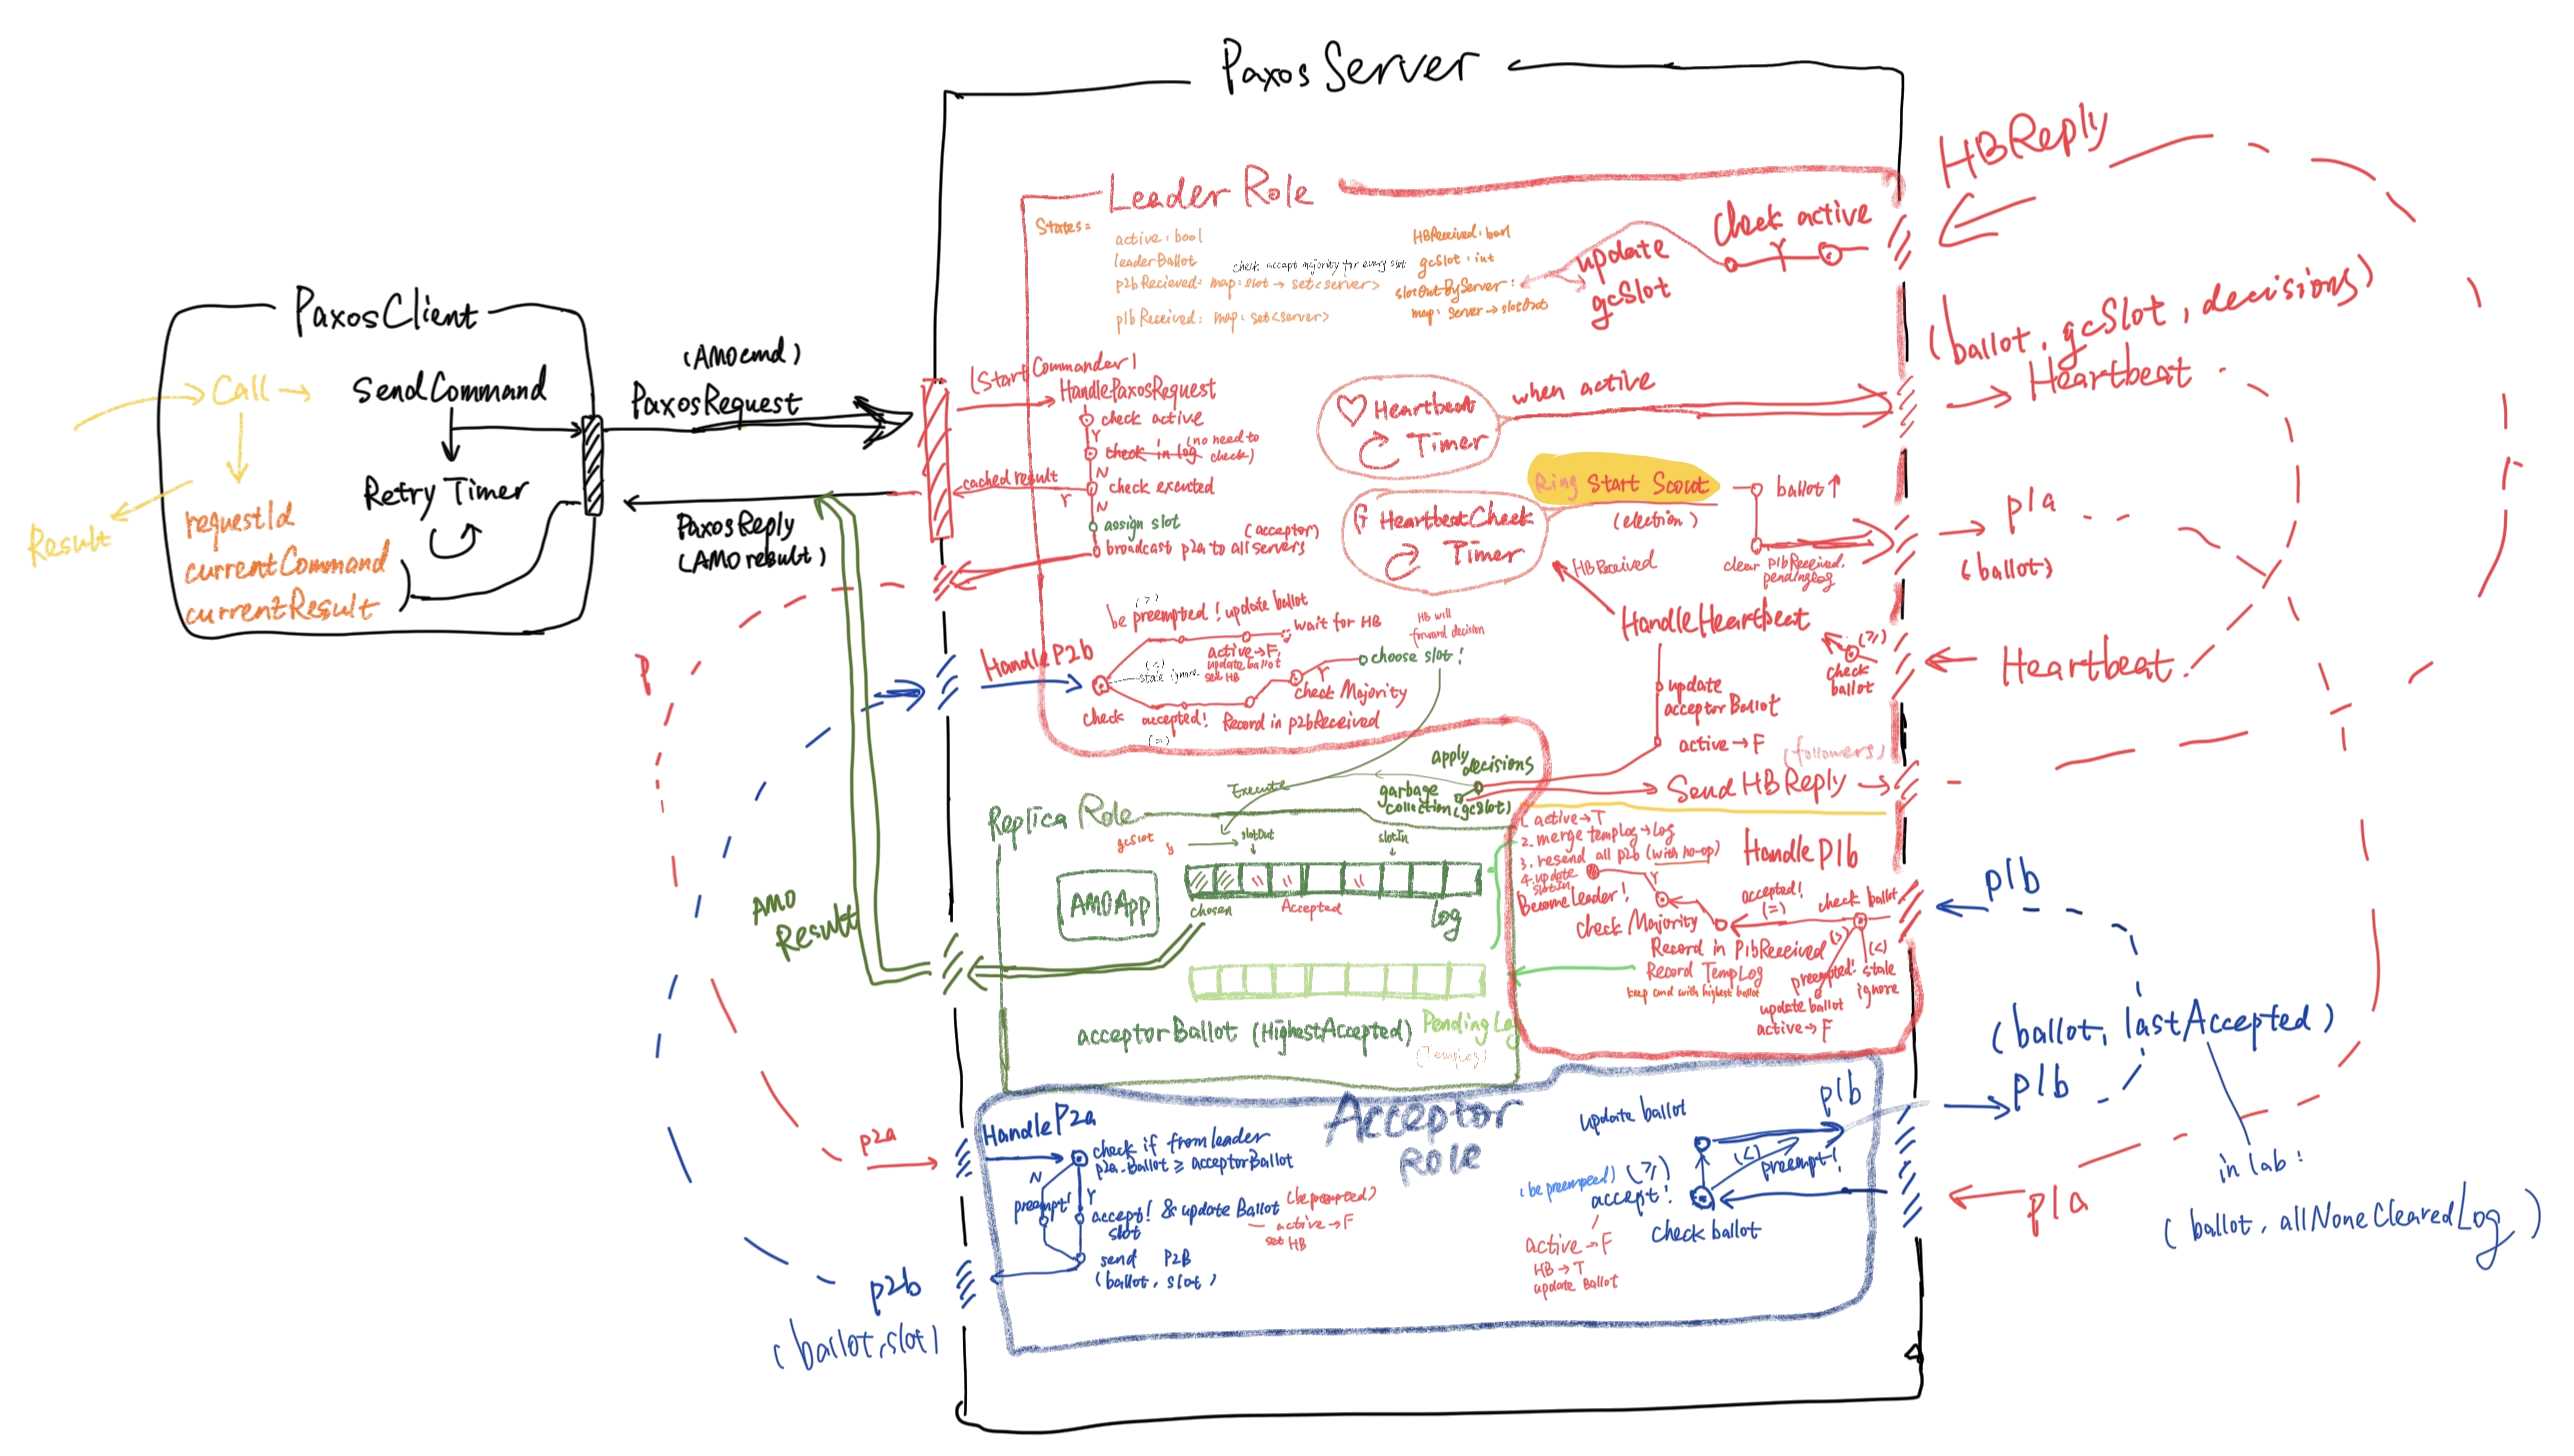
Independently designed and implemented a linearizable distributed key-value store based on Multi-Paxos.
独立设计并实现基于 Multi-Paxos 的线性一致性分布式 KV 存储系统
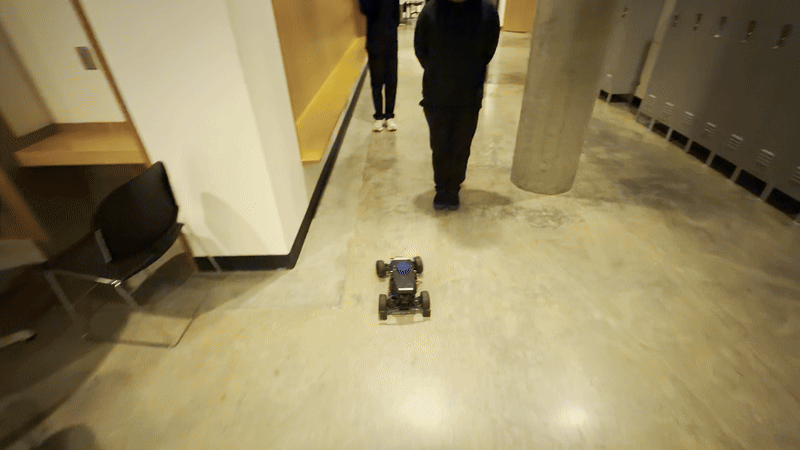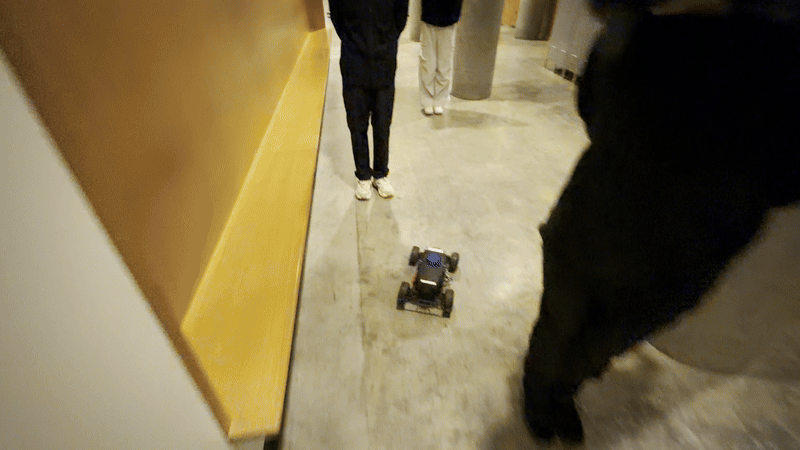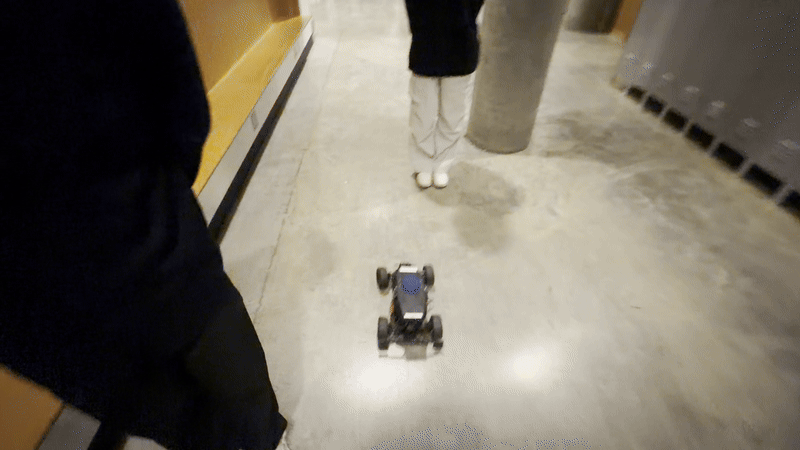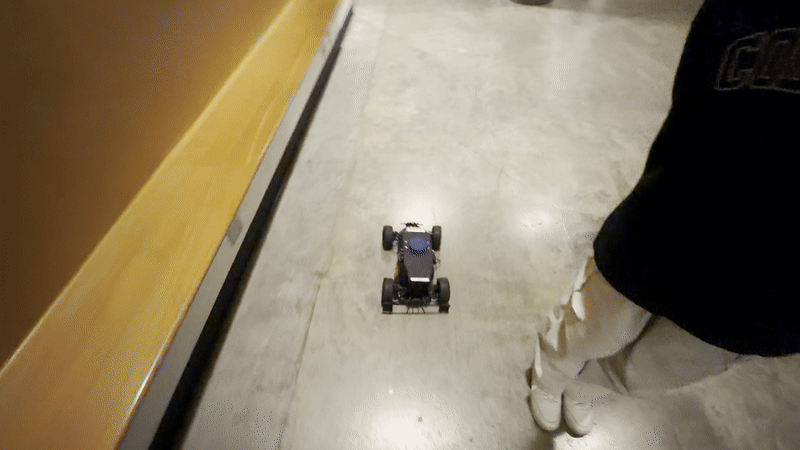
Built a full localization–planning–control stack for autonomous driving with indoor navigation, deployed on an NVIDIA Jetson robot.
搭建定位-规划-控制的自动驾驶全栈系统,实现室内自动导航,部署在 NVIDIA Jetson 小车上
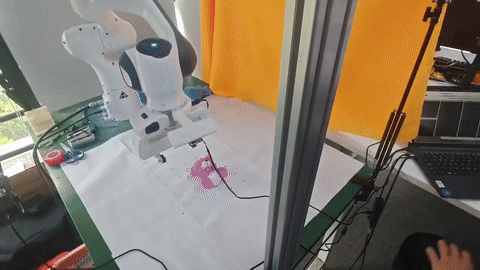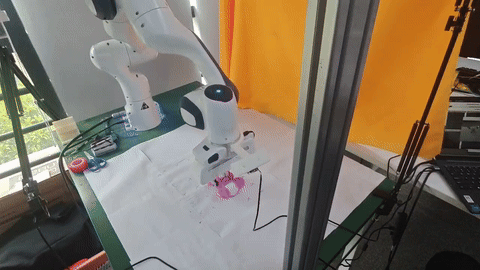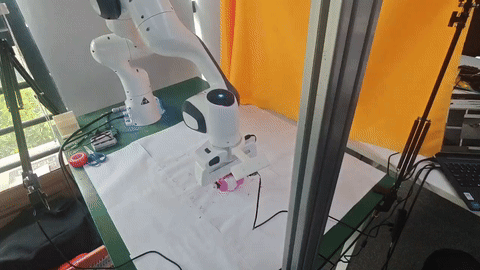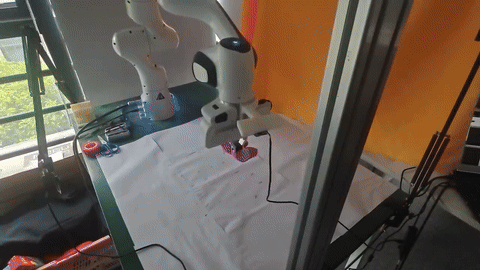
Fine-tuned and deployed the Pi0 VLA model on Franka and humanoid platforms for natural-language grasping tasks.
微调与部署 Pi0 VLA 模型,在 Franka 机械臂与人形机器人上微调模型实现自然语言抓取任务
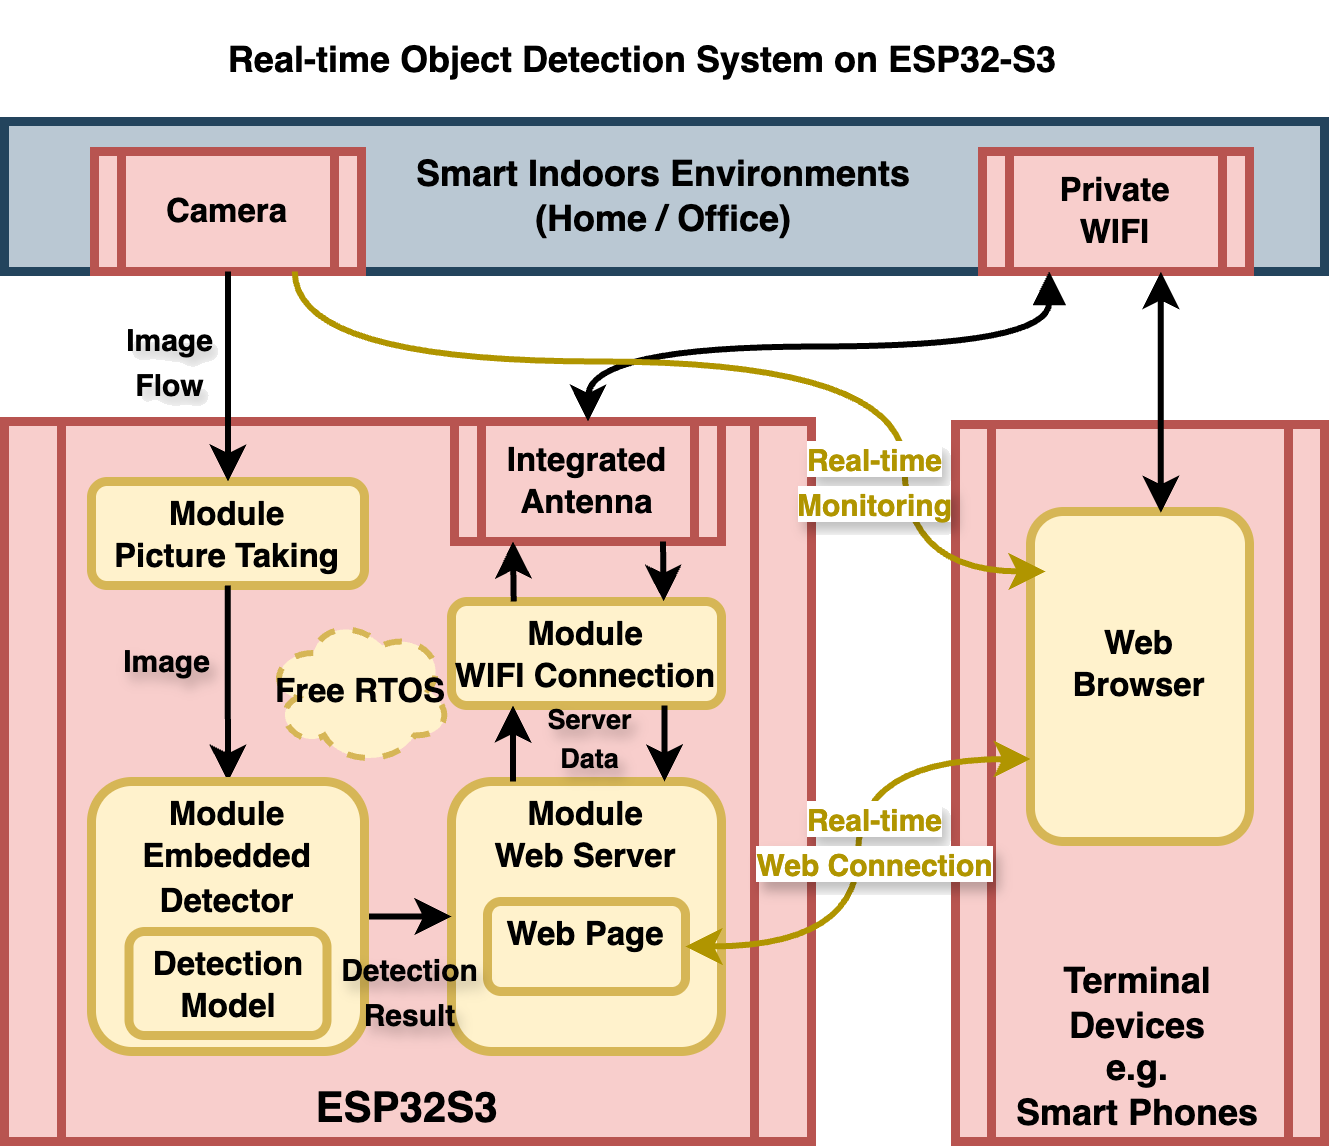
Designed a real-time person-detection pipeline on a microcontroller, with a quantized detector running on ESP32-S3.
设计单片机上的实时人体检测系统,将目标检测模型量化压缩在 ESP32-S3 上
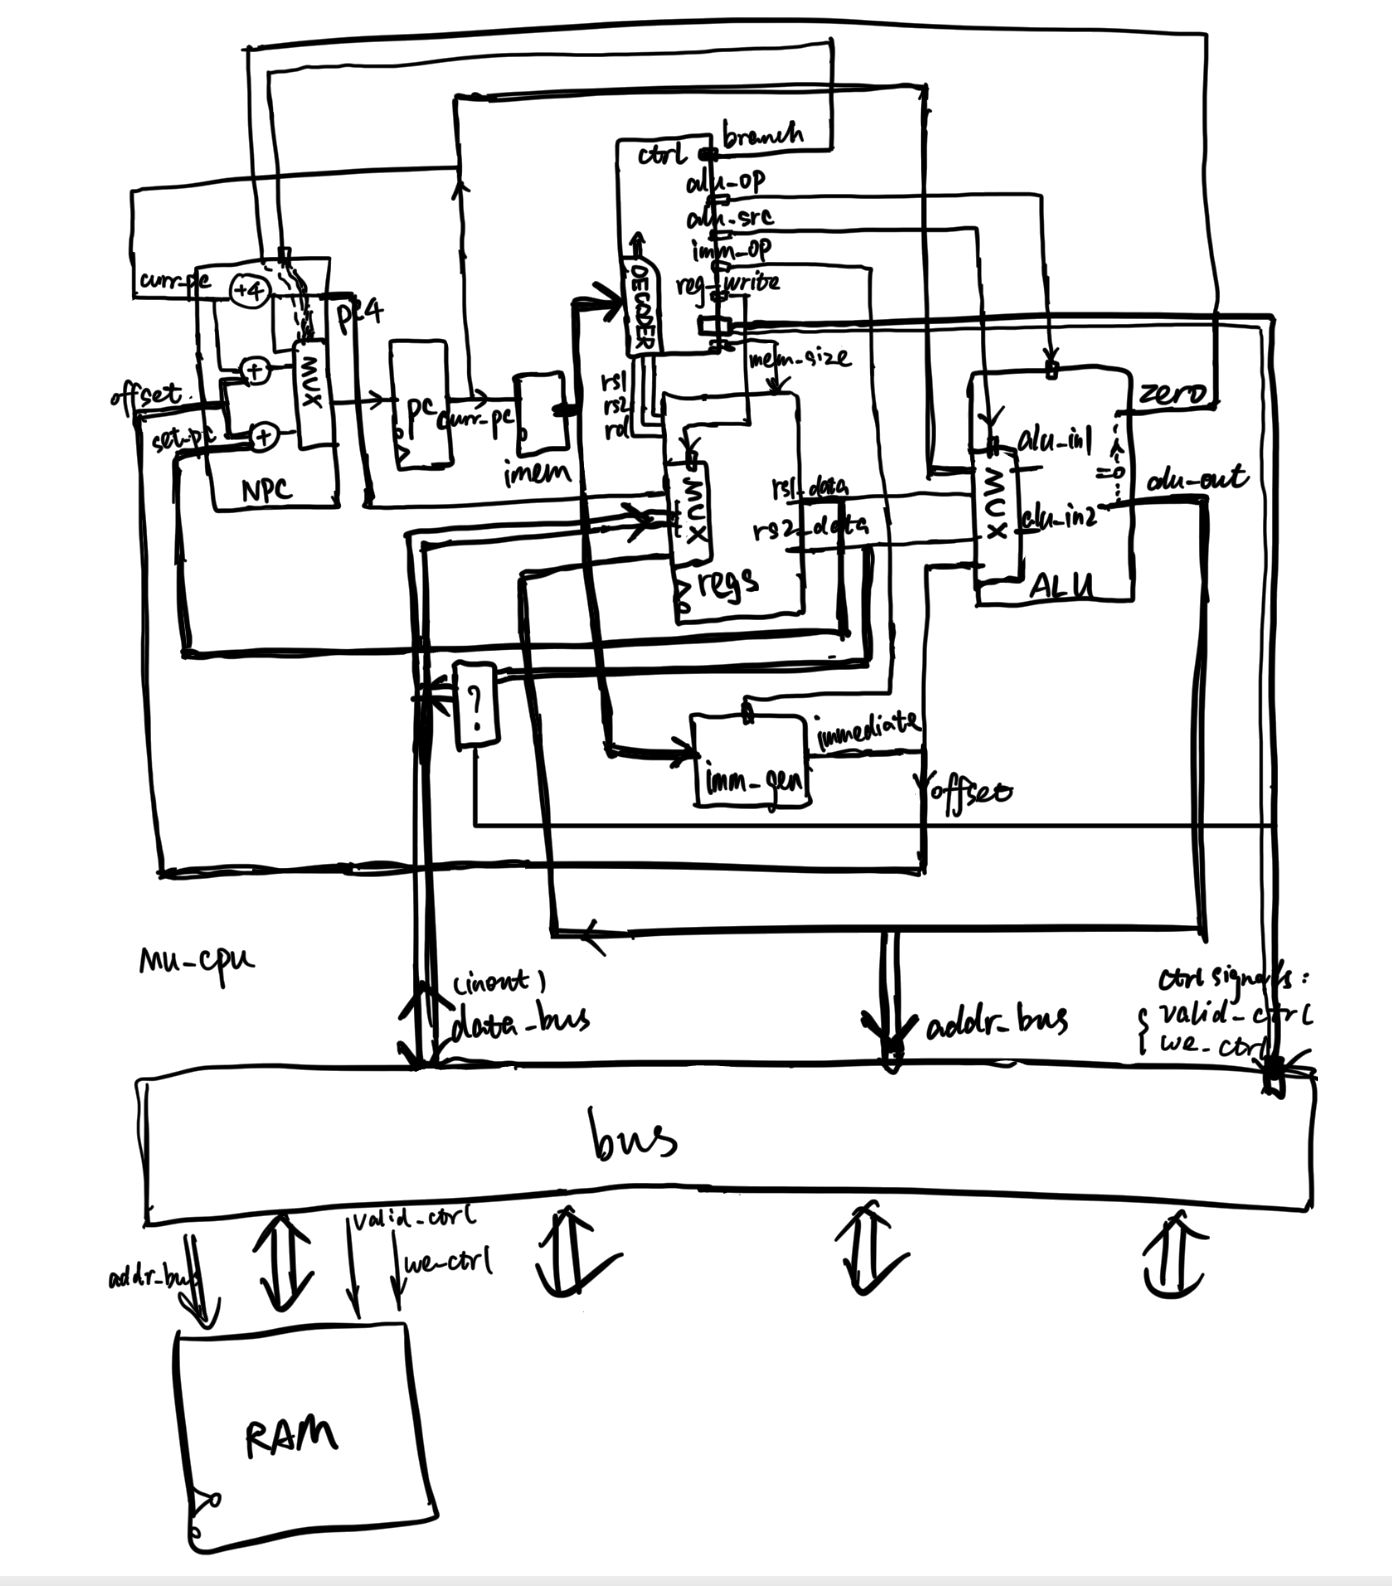
Implemented a single-cycle RISC-V core with full RV32I support in Verilog and brought it up on FPGA.
用 Verilog 实现了支持完整 RV32I 指令集的 RISC-V 单周期处理器,部署在 FPGA 上